Dual arm · Mobile
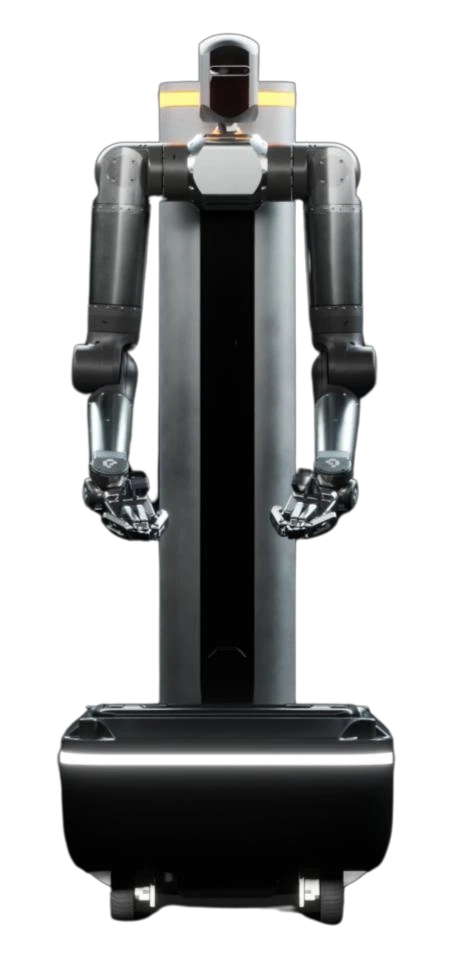
PR-OMNI
A mobile robot that moves between stations and works with both hands.
- Degrees of freedom
- 30
- Payload
- 10 kg
- Height
- 1.7 m
- Top speed
- 2 m/s

How it's built
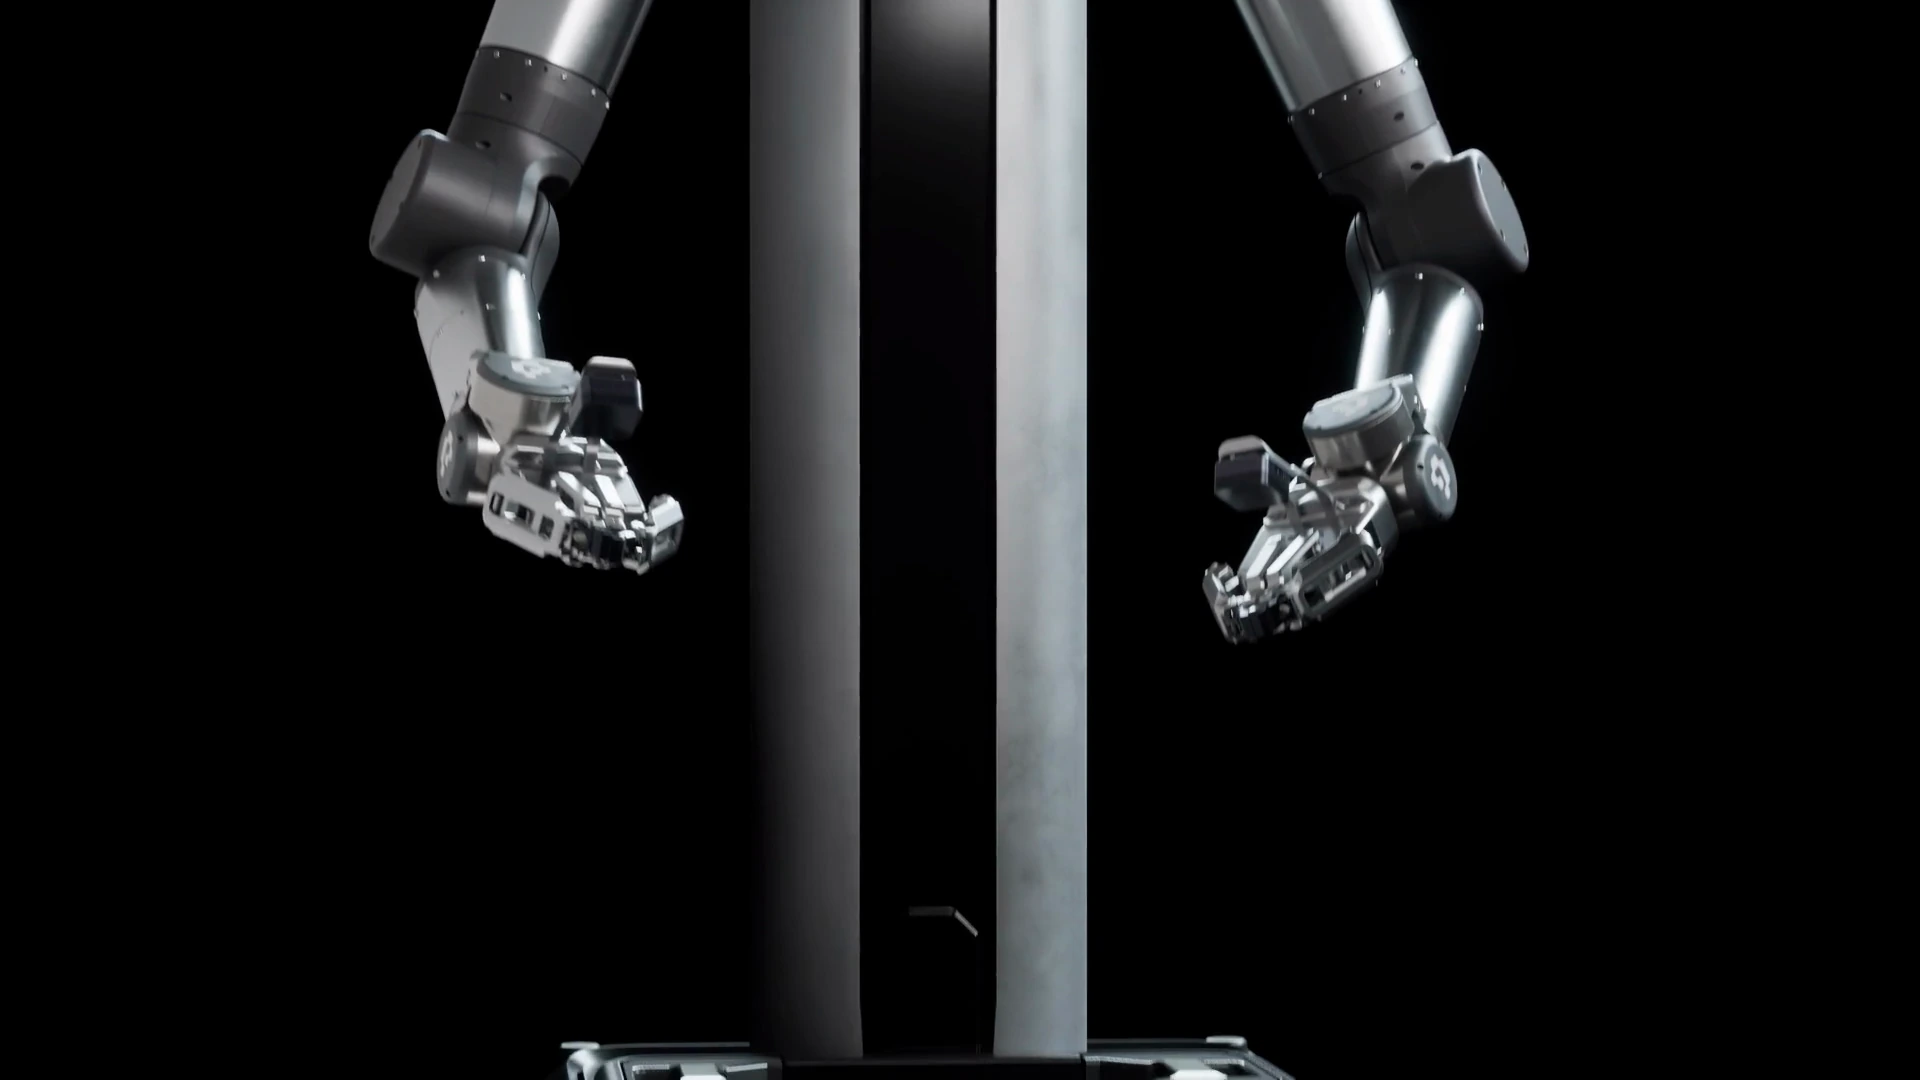
Arms
- Force-aware Senses every contact, and adjusts its force.
- 7 DoF Reaches around obstacles, as a human arm does.
- Sleek and compact Slim enough for tight workcells.
- Two arms Holds both parts of an assembly, so it needs no fixtures.
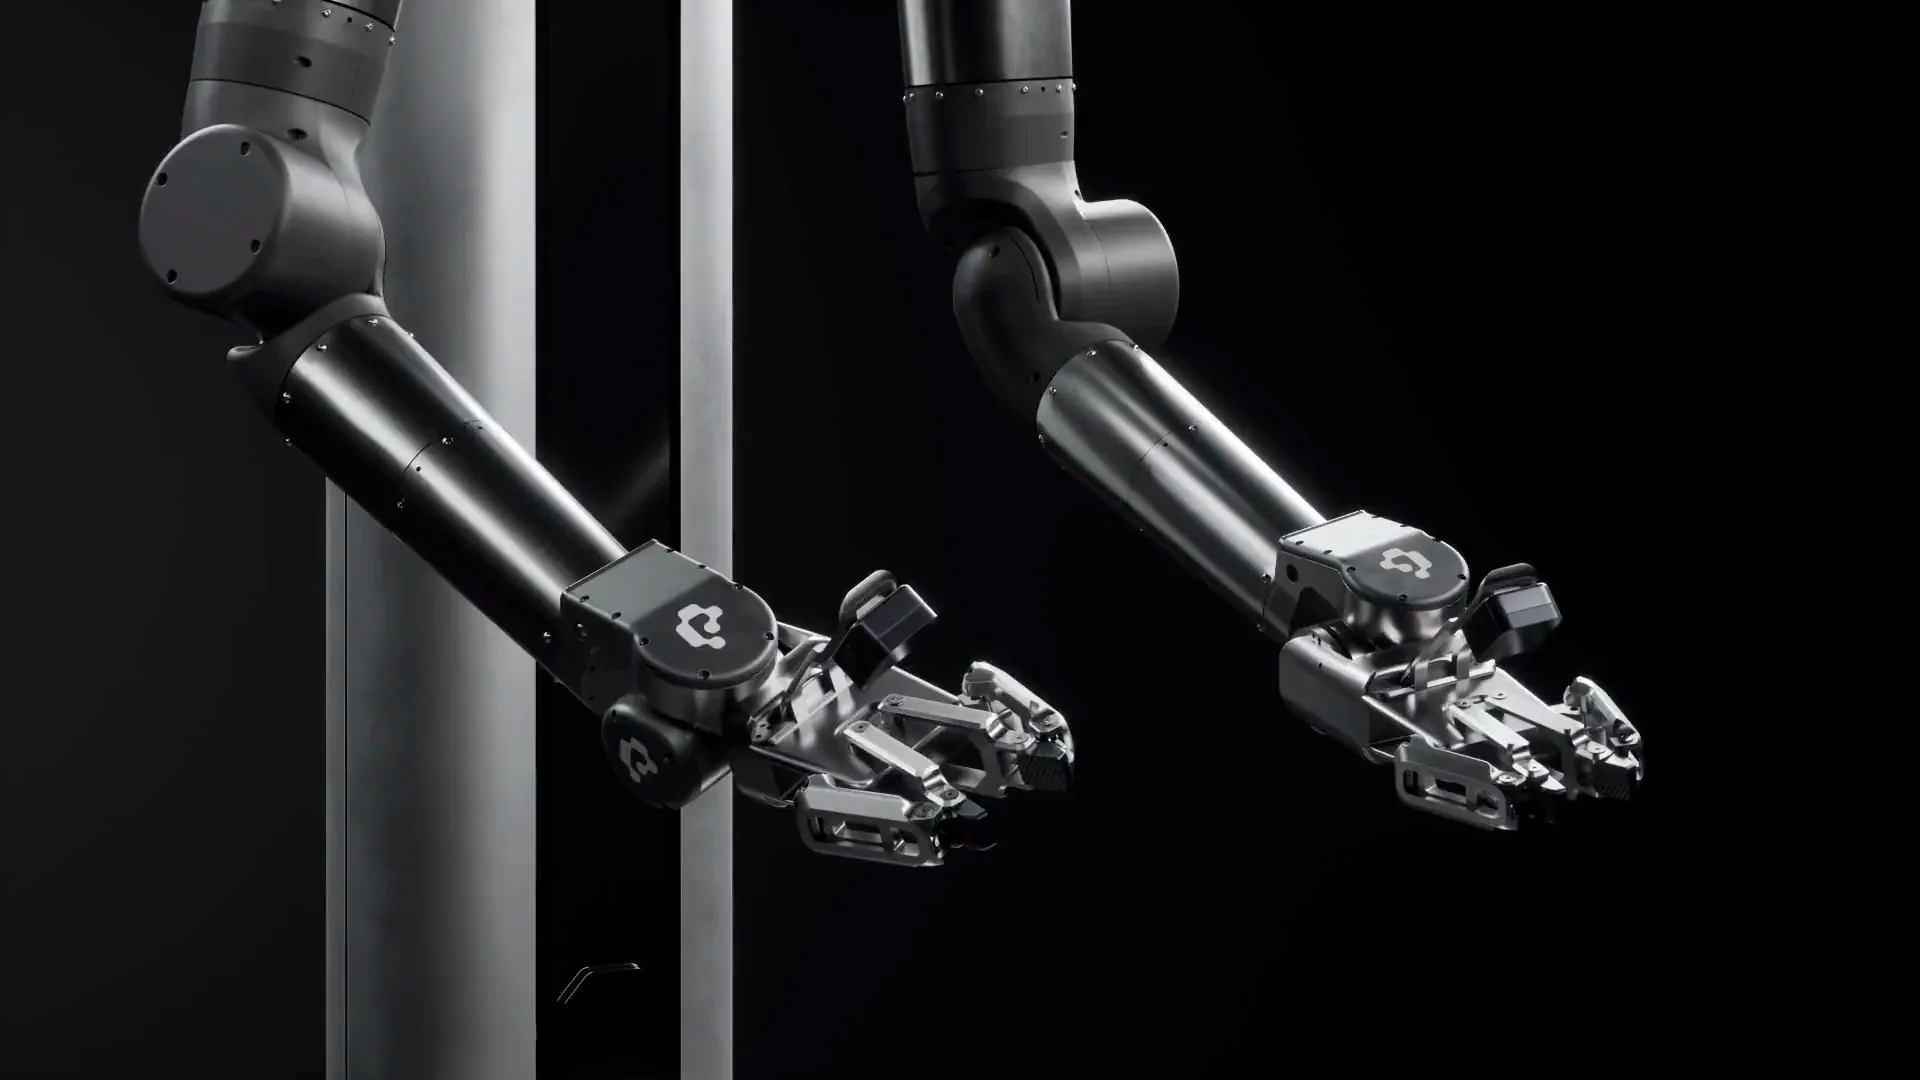
Hands
- In-hand manipulation Turns and repositions a part without setting it down.
- Tactile sensing Feels what it holds, by touch.
- Force-aware Grips firmly or gently, as each part needs.
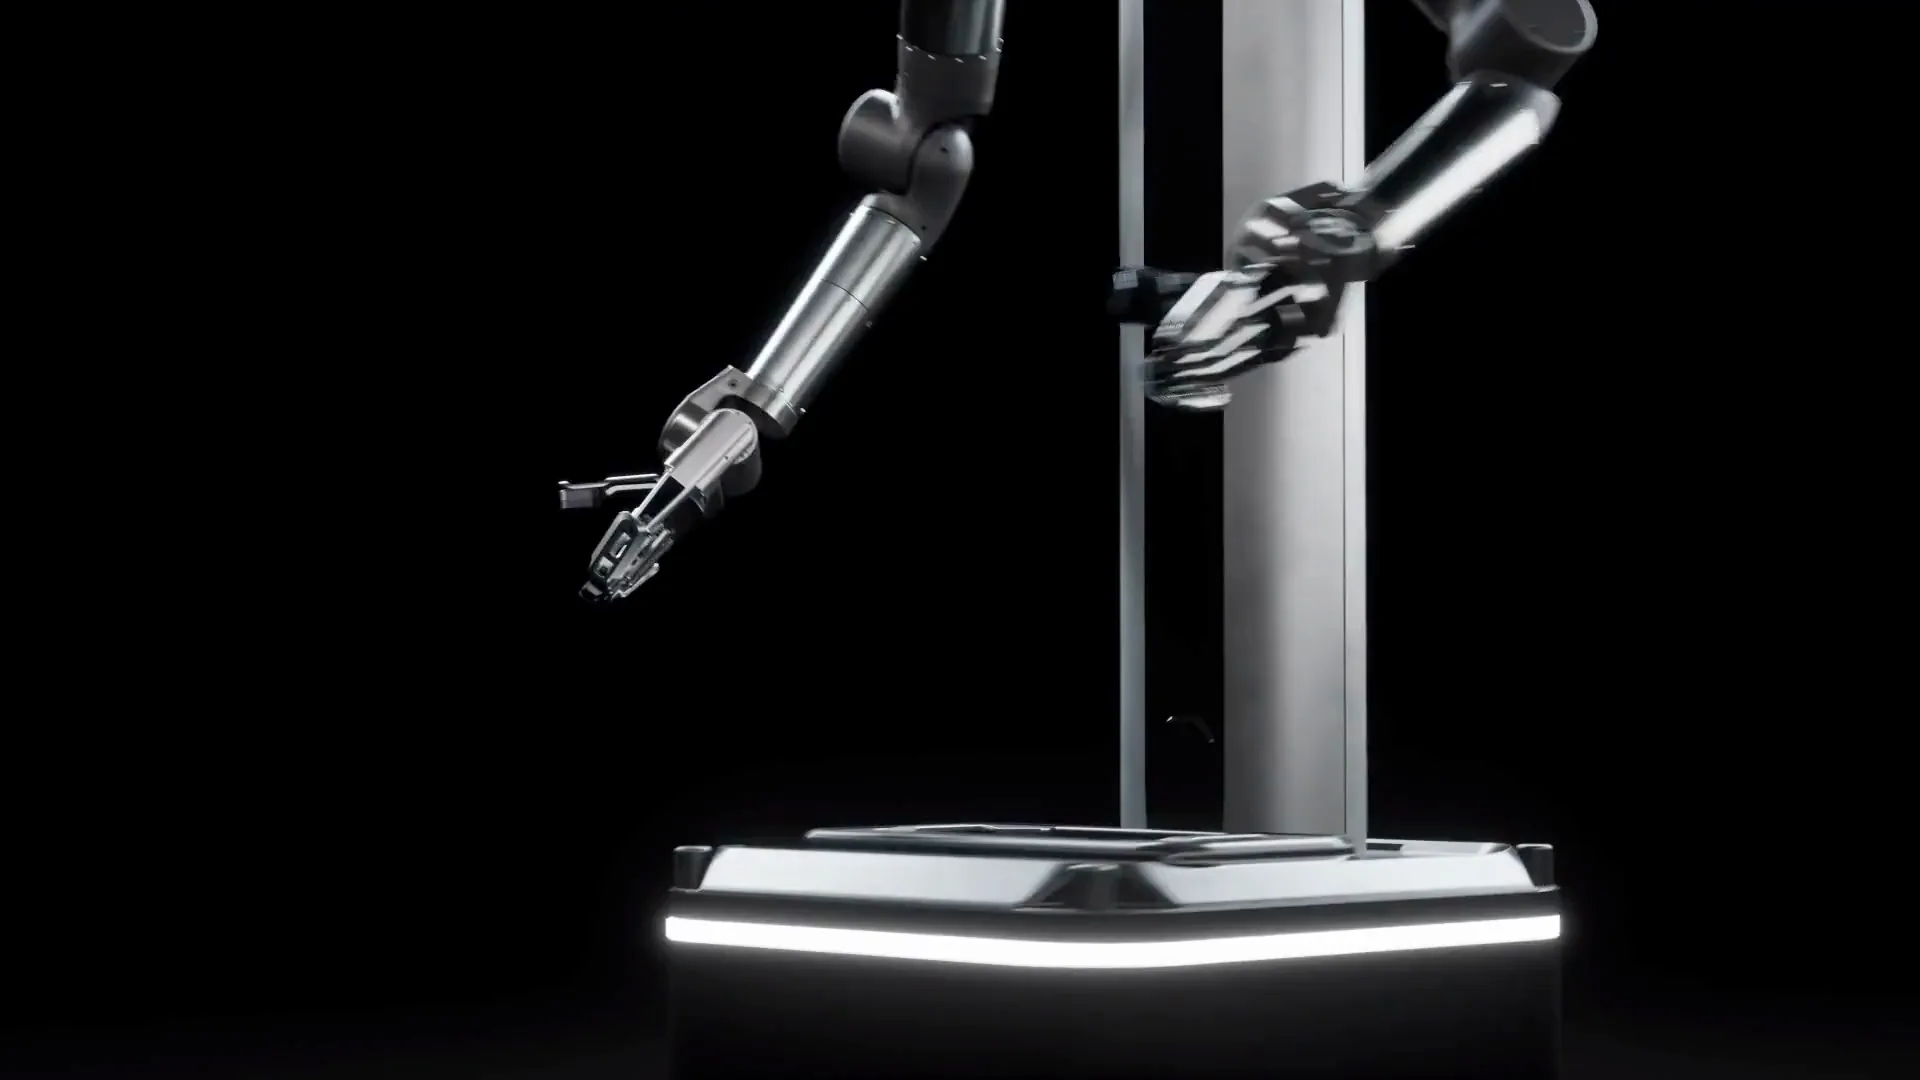
Base
- Holonomic drive Four-wheel swerve drive: moves in any direction and turns on the spot.
- Gantry Raises and lowers the body, for the most reach.
- Sensors A LiDAR and three stereo cameras on the base.
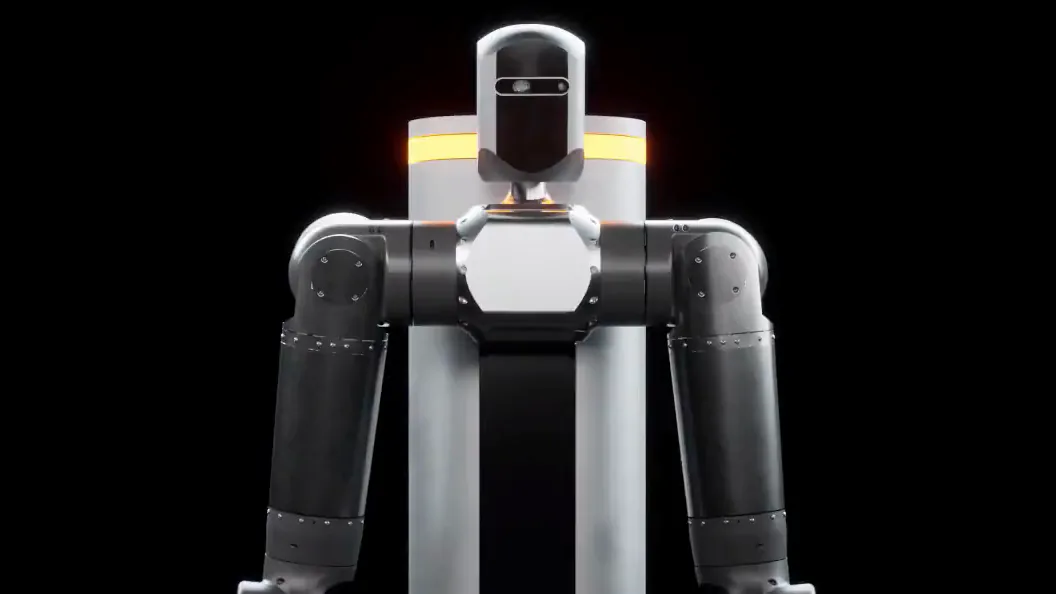
Head
- 4 DoF movable head A stereo camera on a 4 DoF mini-arm, extending and turning for the best view.
- Powered by PR-PHI Visual servoing, force-aware feedback and many more skills.
Skills, with PR-PHI
See PR-PHI- Visual servo
- Reaches the workpiece despite jig and position errors.
- Reaches objects in motion, on a conveyor or from a mobile base.
- Adapts to flexible workpieces.
- Peg-in-a-hole / snap fit
- Force-feedback adaptive assembly: mating connectors, bolts and boxes seated without damage.
- Corrects its own position from force signatures. No exact coordinates needed.
- Coordinated hand-over
- Moves both arms as one, so large objects never slip out of hand.
- Assembles with both hands together.
- Short-range navigation
- Fetches the components it needs from the stations around it.
- Works on mobile conveyor belts.
- Localises by ArUco markers and wheel odometry.
- Long-range navigationIn development
- Moves material from one place to another across a shop floor.
- Stows and retrieves material from shelves, for end-to-end automation.
- Tele-operationIn development
- A person in the loop, for supervision and fail-safe operation.
- Collects data continuously, for physical intelligence and shared autonomy.
Where it works
See solutions
Electronics
Connectors seated by feel.

Automotive
Hub bolts torqued in pairs.

Warehouse
Cartons picked into totes.

Food & produce
Fruit turned and packed.
Specifications
Tentative specifications.
Basic
- Degrees of freedom7 in each arm, 4 steering, 4 wheels, 4 in the head mount, 2 in each end effector
- 30 in total
- Payload
- 10 kg, both arms
- Dimensions
- 0.6 × 0.6 × 1.7 m
- Weight
- 110 kg
- Operating temperature
- 0–45 °C
Performance
- Base positioning accuracy
- ± 30 mm
- Base maximum climb
- 5°
- Base maximum speed
- 2 m/s
- Base maximum acceleration
- 2 m/s²
- Gantry maximum speed
- 0.3 m/s
- TCP maximum speed
- 2 m/s
Power and connectivity
- Power requirement
- 220 V, 15 A, charging
- Power consumption
- 1500 W
- Battery capacity
- 3 kWh or 6 kWh
- Connectivity
- Wi-Fi
More robots
-

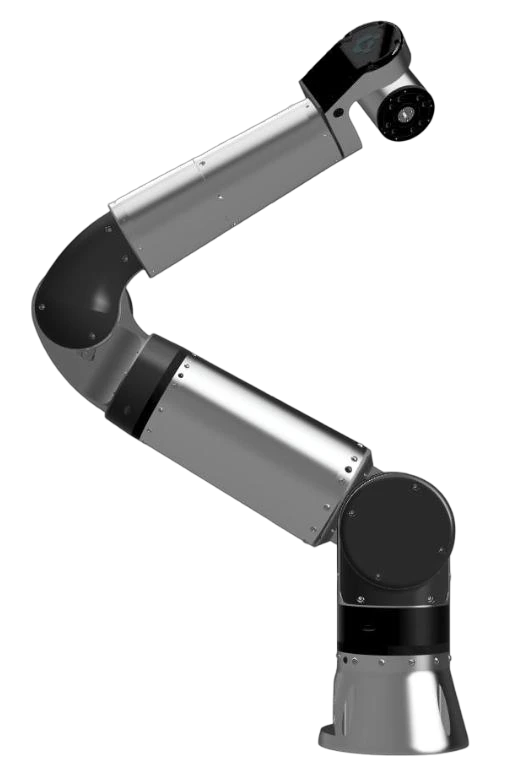
Single arm
PR-UNO
A dexterous arm that mounts anywhere and feels its way through precise assembly.
Explore PR-UNO -

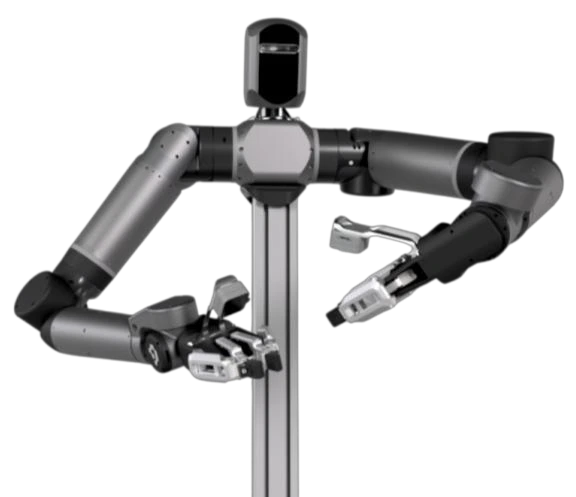

Dual arm · Station
PR-DUO
Two coordinated arms on a compact station, for two-handed work in tight spaces.
Explore PR-DUO