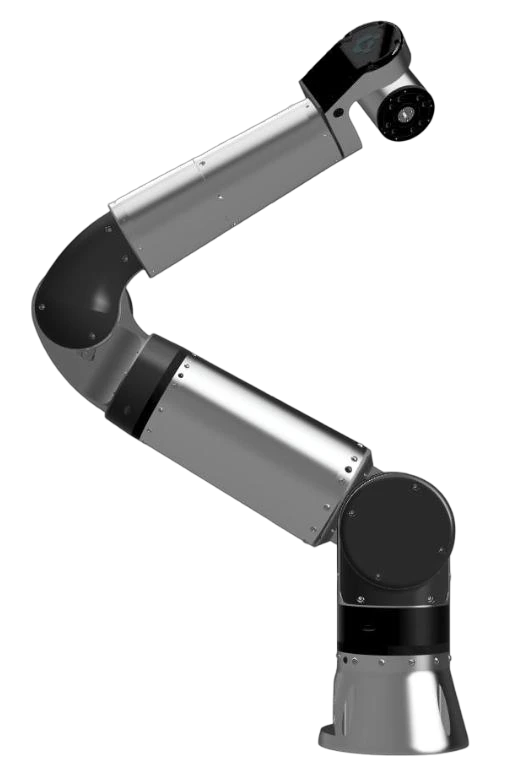
Single arm
PR-UNO
A dexterous arm that mounts anywhere and feels its way through precise assembly.
- Degrees of freedom
- 7
- Payload
- 5 kg
- Reach
- 850 mm
- Repeatability
- ± 0.2 mm

How it's built
- 7 DoF
- Reaches objects behind others.
- Smooth, incremental movement everywhere.
- Avoids obstacles more easily.
- Torque feedback at every jointIn development
- Makes contact-rich assembly possible.
- Controls force over a large working envelope.
- Works alongside people.
- True spherical joints
- At the shoulder and the wrist, for compact moves at the wrist.
- Human-like, so it is easier to tele-operate.
- Multiple control modes
- Position, velocity, torque and impedance control.
- Trajectory and instantaneous control, up to 1 kHz.
- SafetyIn development
- ISO 15066 compliant.
Skills, with PR-PHI
See PR-PHI- Visual servo
- Reaches the workpiece despite jig and position errors.
- Reaches objects in motion, on a conveyor or from a mobile base.
- Adapts to flexible workpieces.
- Peg-in-a-hole / snap fit
- Force-feedback adaptive assembly: mating connectors, bolts and boxes seated without damage.
- Corrects its own position from force signatures. No exact coordinates needed.
- Surface finishingIn development
- Force-feedback grinding and buffing over a large working envelope.
- Needs only a few waypoints, not an exact trajectory.
Where it works
- Connector insertion Mating connectors seated without damage.
- RAM insertion Memory modules seated by feel.
- Flex PC insertion Flex cables placed by feel.
- Bolt insertion Fasteners found and driven home.
- Grinding and buffingIn development Surfaces finished with force feedback.
Specifications
Basic
- Degrees of freedom
- 7
- Payload
- 5 kg
- Reach
- 850 mm
- Installation position
- Any
- Weight
- 18 kg
- Operating temperature
- 0–50 °C
- Footprint
- 150 mm
Performance
- TCP pose repeatability
- ± 0.2 mm
- TCP force sensing accuracy
- ± 0.2 N
- TCP torque sensing accuracy
- ± 0.2 Nm
- TCP maximum speed
- 2 m/s
- TCP maximum acceleration
- 2 m/s²
Movement
| Joint | Range | Max speed |
|---|---|---|
| J1 | −180° to 180° | 150°/s |
| J2 | 0° to 180° | 150°/s |
| J3 | −180° to 180° | 180°/s |
| J4 | 0° to 135° | 180°/s |
| J5 | −180° to 180° | 180°/s |
| J6 | −30° to 210° | 180°/s |
| J7 | −180° to 180° | 180°/s |
End-effector interface
- Power supply
- 48 V, 2 A
- Control interface
- RS-485
Power and connectivity
- Power requirement
- 220 V, 5 A
- Power consumption
- 600 W
- Connectivity
- Ethernet
More robots
-

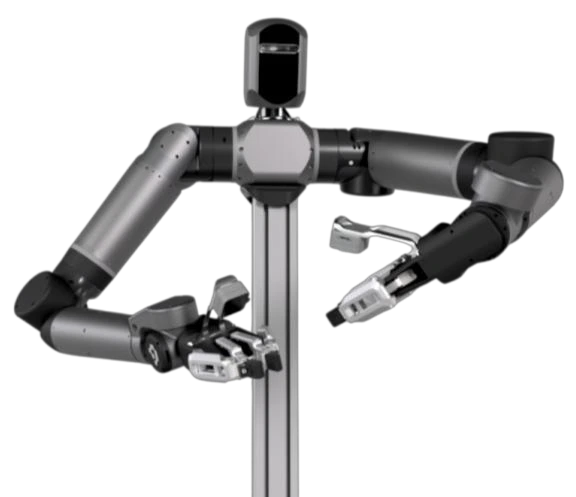

Dual arm · Station
PR-DUO
Two coordinated arms on a compact station, for two-handed work in tight spaces.
Explore PR-DUO -

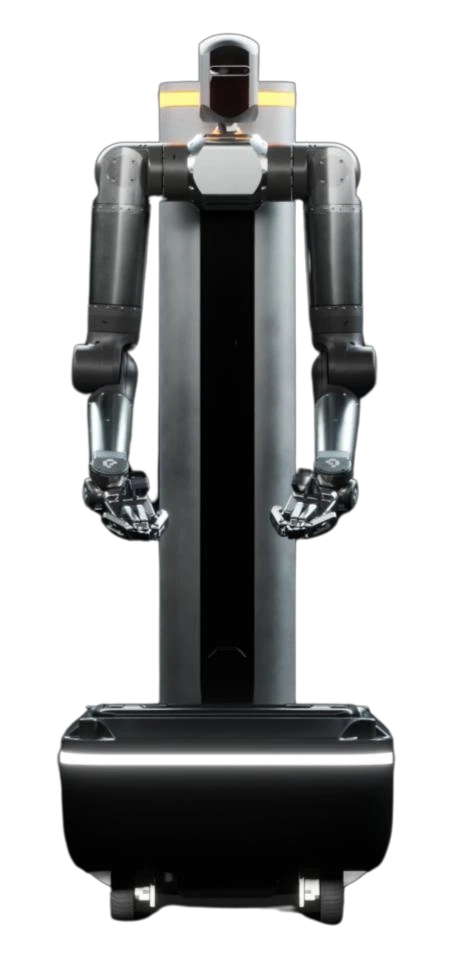
Dual arm · Mobile
PR-OMNI
A mobile robot that moves between stations and works with both hands.
Explore PR-OMNI