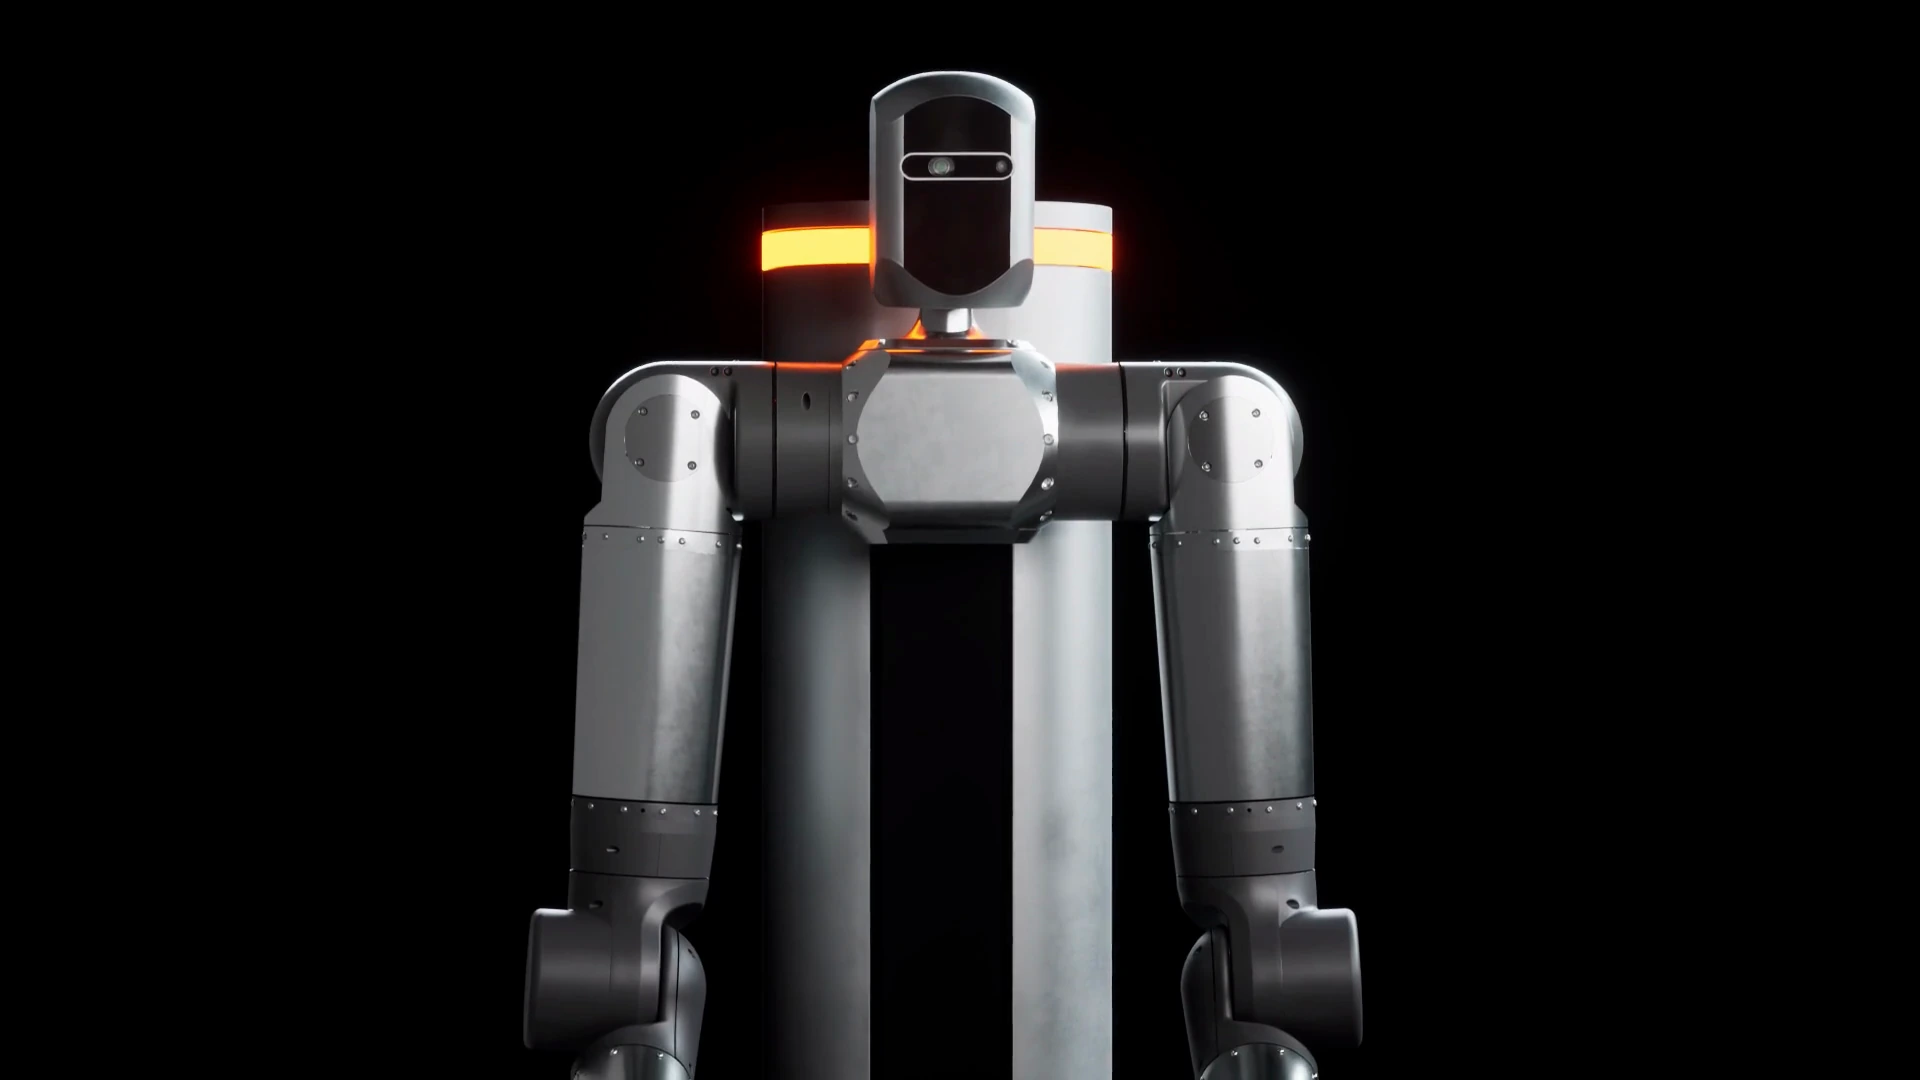
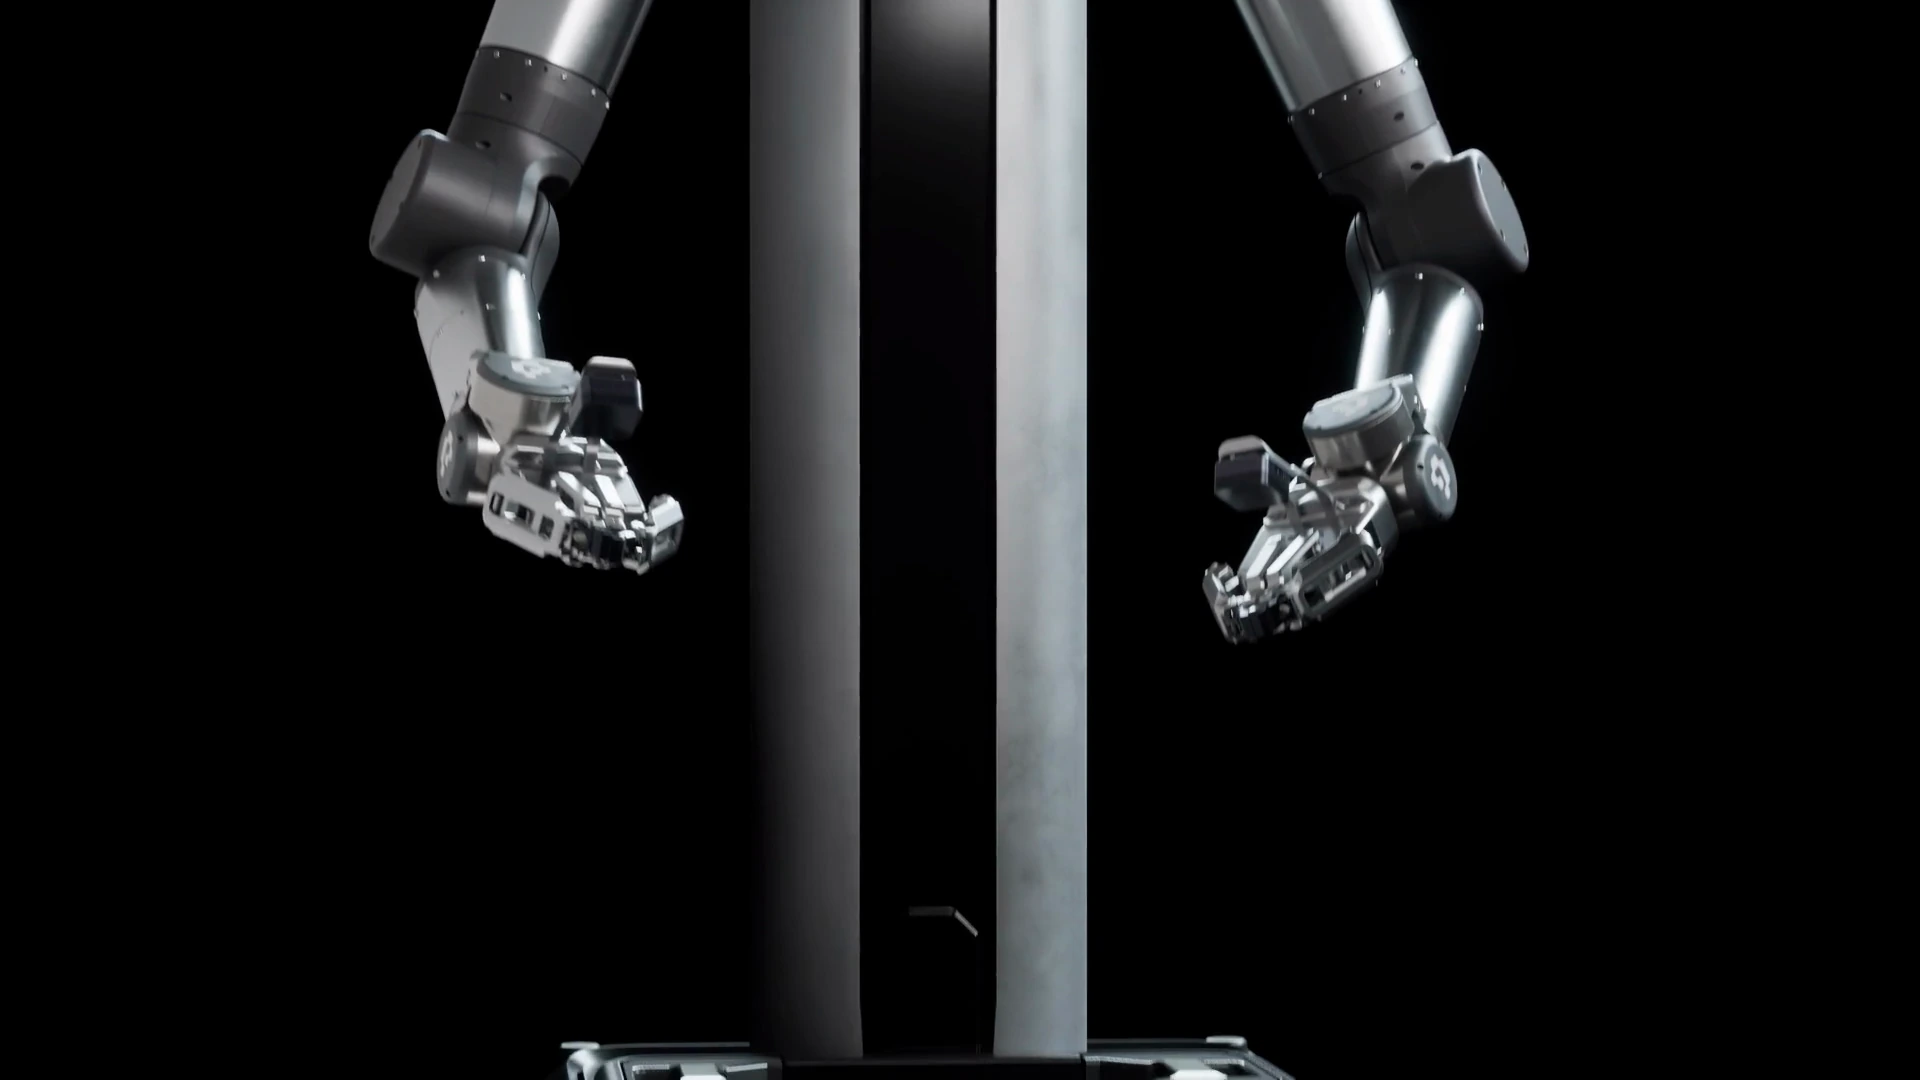
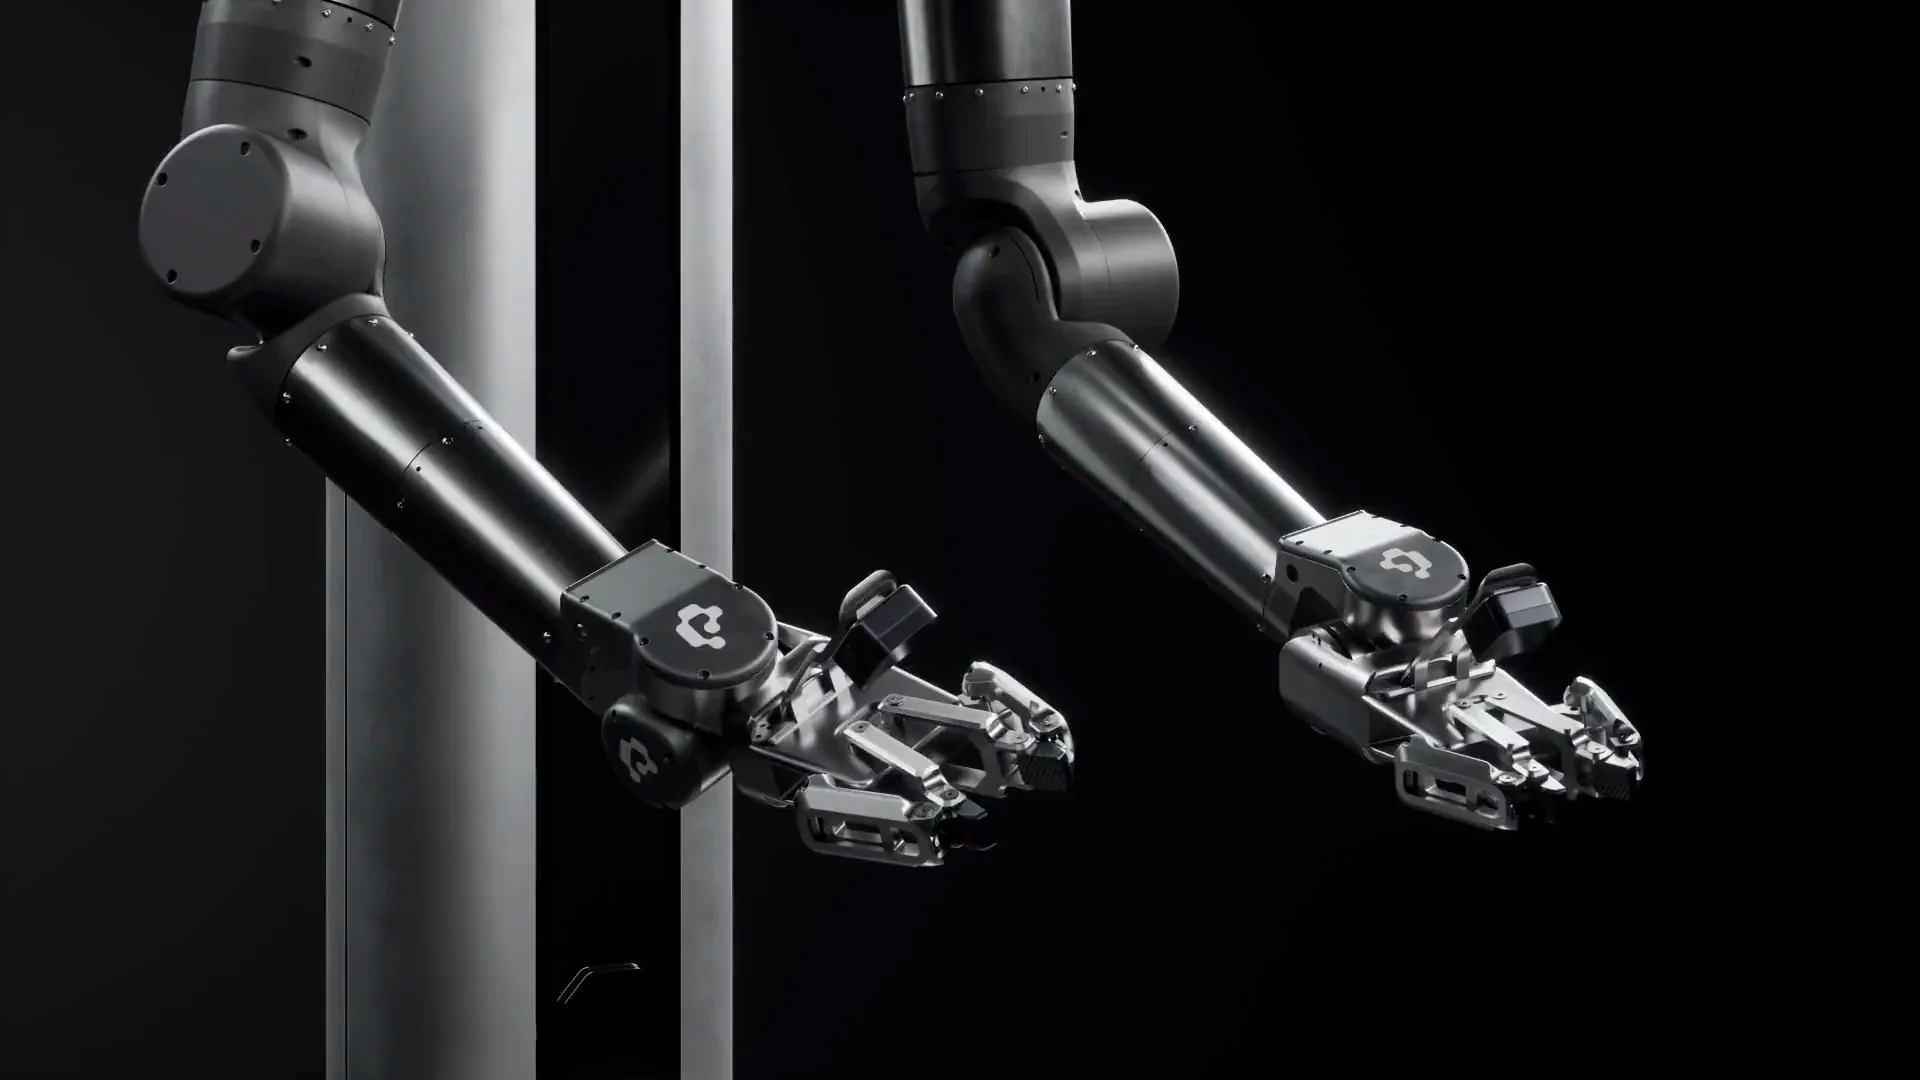
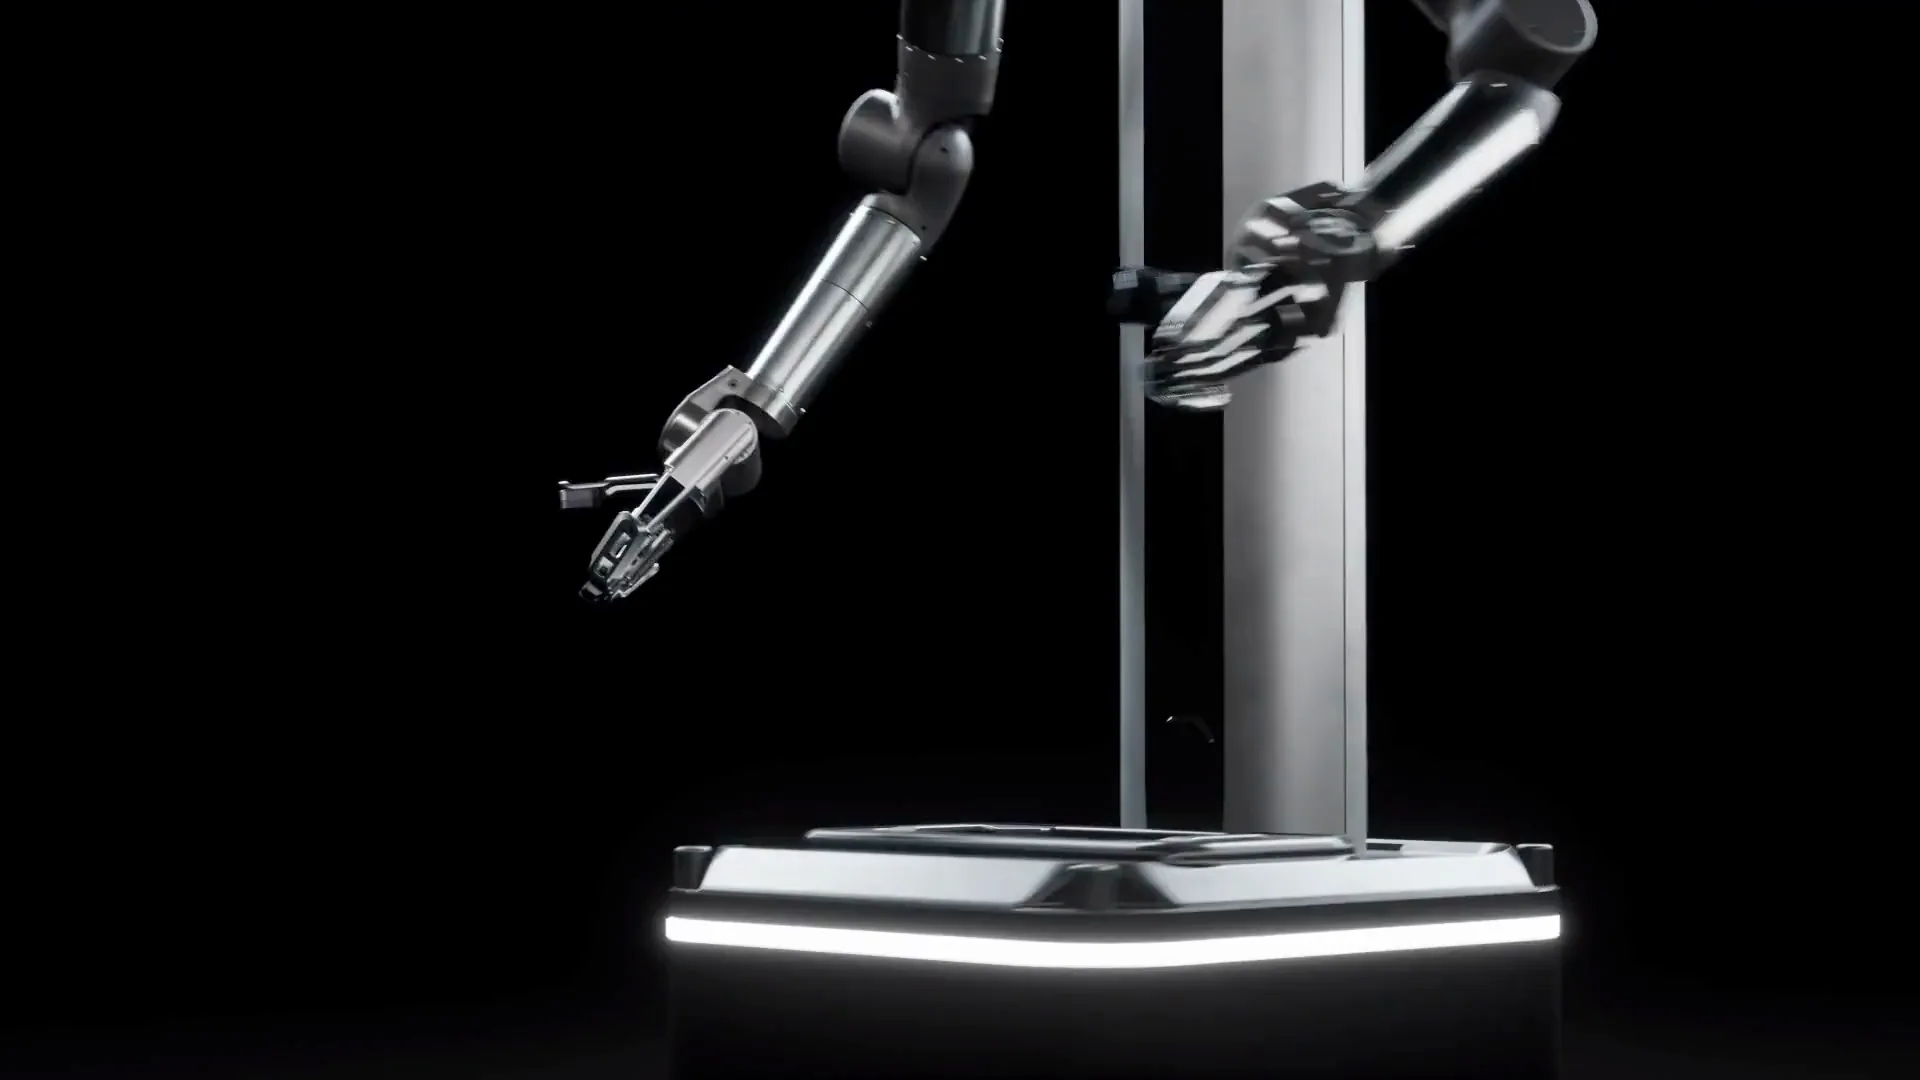
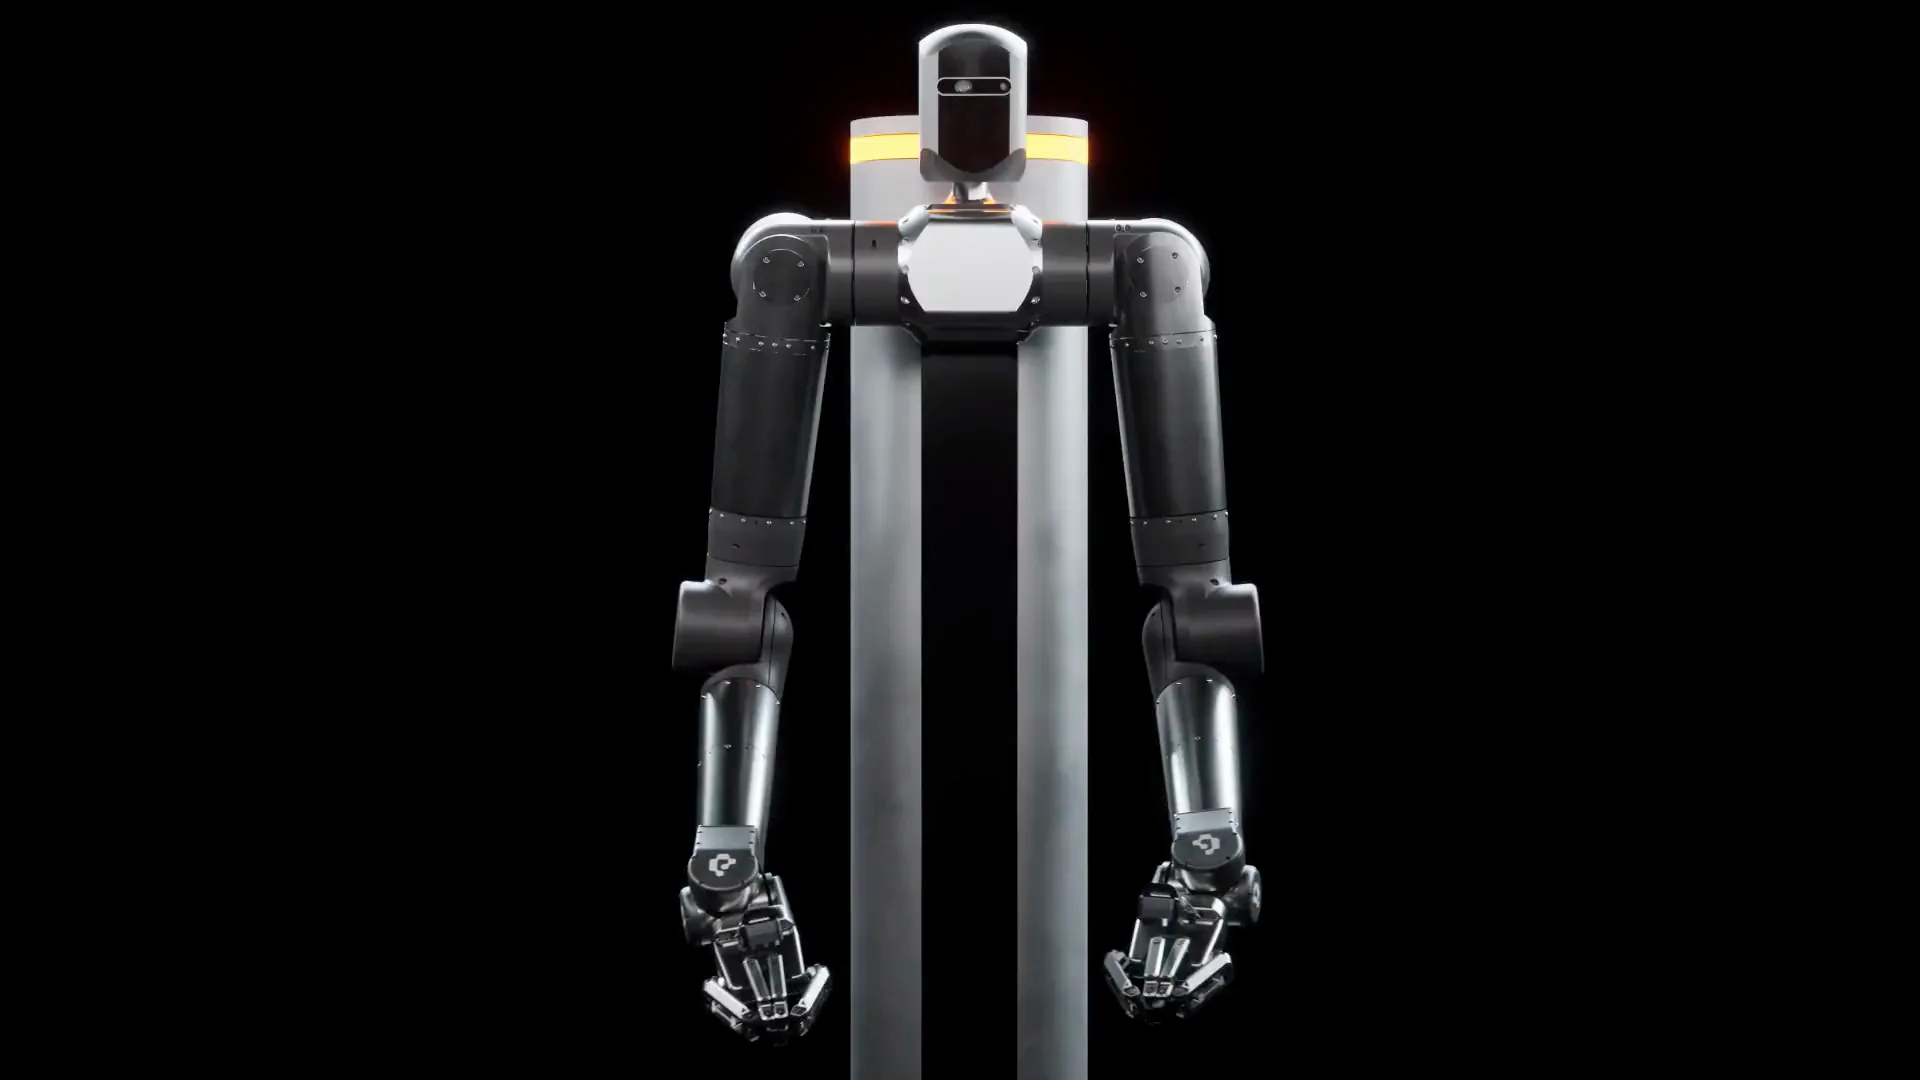
Arms
- Force-awareSenses every contact, and adjusts its force.
- 7 DoFReaches around obstacles, as a human arm does.
- Sleek and compactSlim enough for tight workcells.

 Contact us
Dexterous hardware. Intelligent movement.
Traditional robots struggle with tasks that need dexterity, intelligence
and adaptability.
We engineer the hardware and Physical AI together.


PR-OMNI Integrated robotic platform


One instruction in. PR-PHI’s task planner lays out the steps, with no code.
Each step runs on proven skills, trained on real industrial data. Not one opaque model.
Vision finds the header wherever the board sits. Touch tells it when the connector is home.
The touch it read was felt here, in the wrist, by the torque sensor beside the drive that moves it.
One task, followed from the instruction down to the joint. The task, pick from any pose, then insert, is laid out as steps: pick, then insert. Insert runs its skills in turn: in-hand manipulation, coarse navigation, visual servo, peg-in-a-hole insertion, state check. Peg-in-a-hole insertion sees the header with vision and feels the connector go in by touch. That touch is felt in the wrist joint, by its torque sensor, beside the motor drive and encoder.


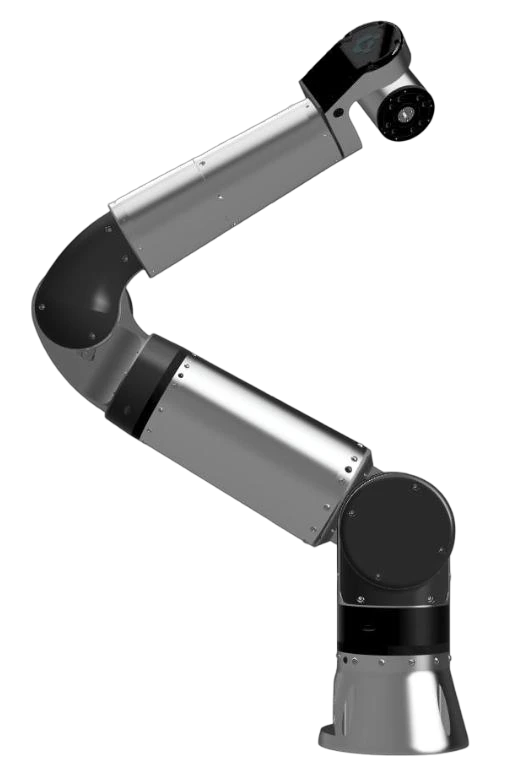
Single arm
A dexterous arm that mounts anywhere and feels its way through precise assembly.
Explore PR-UNO
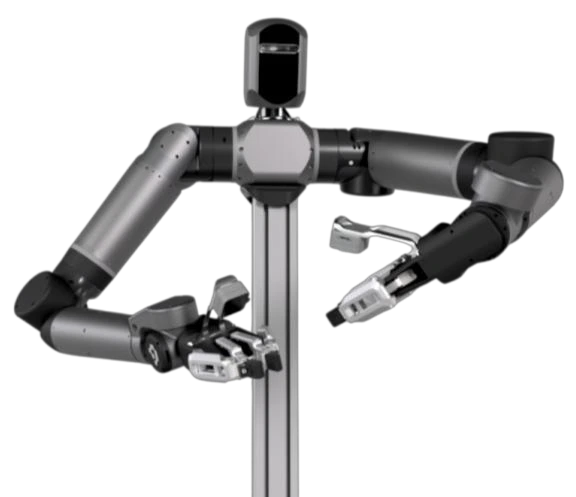

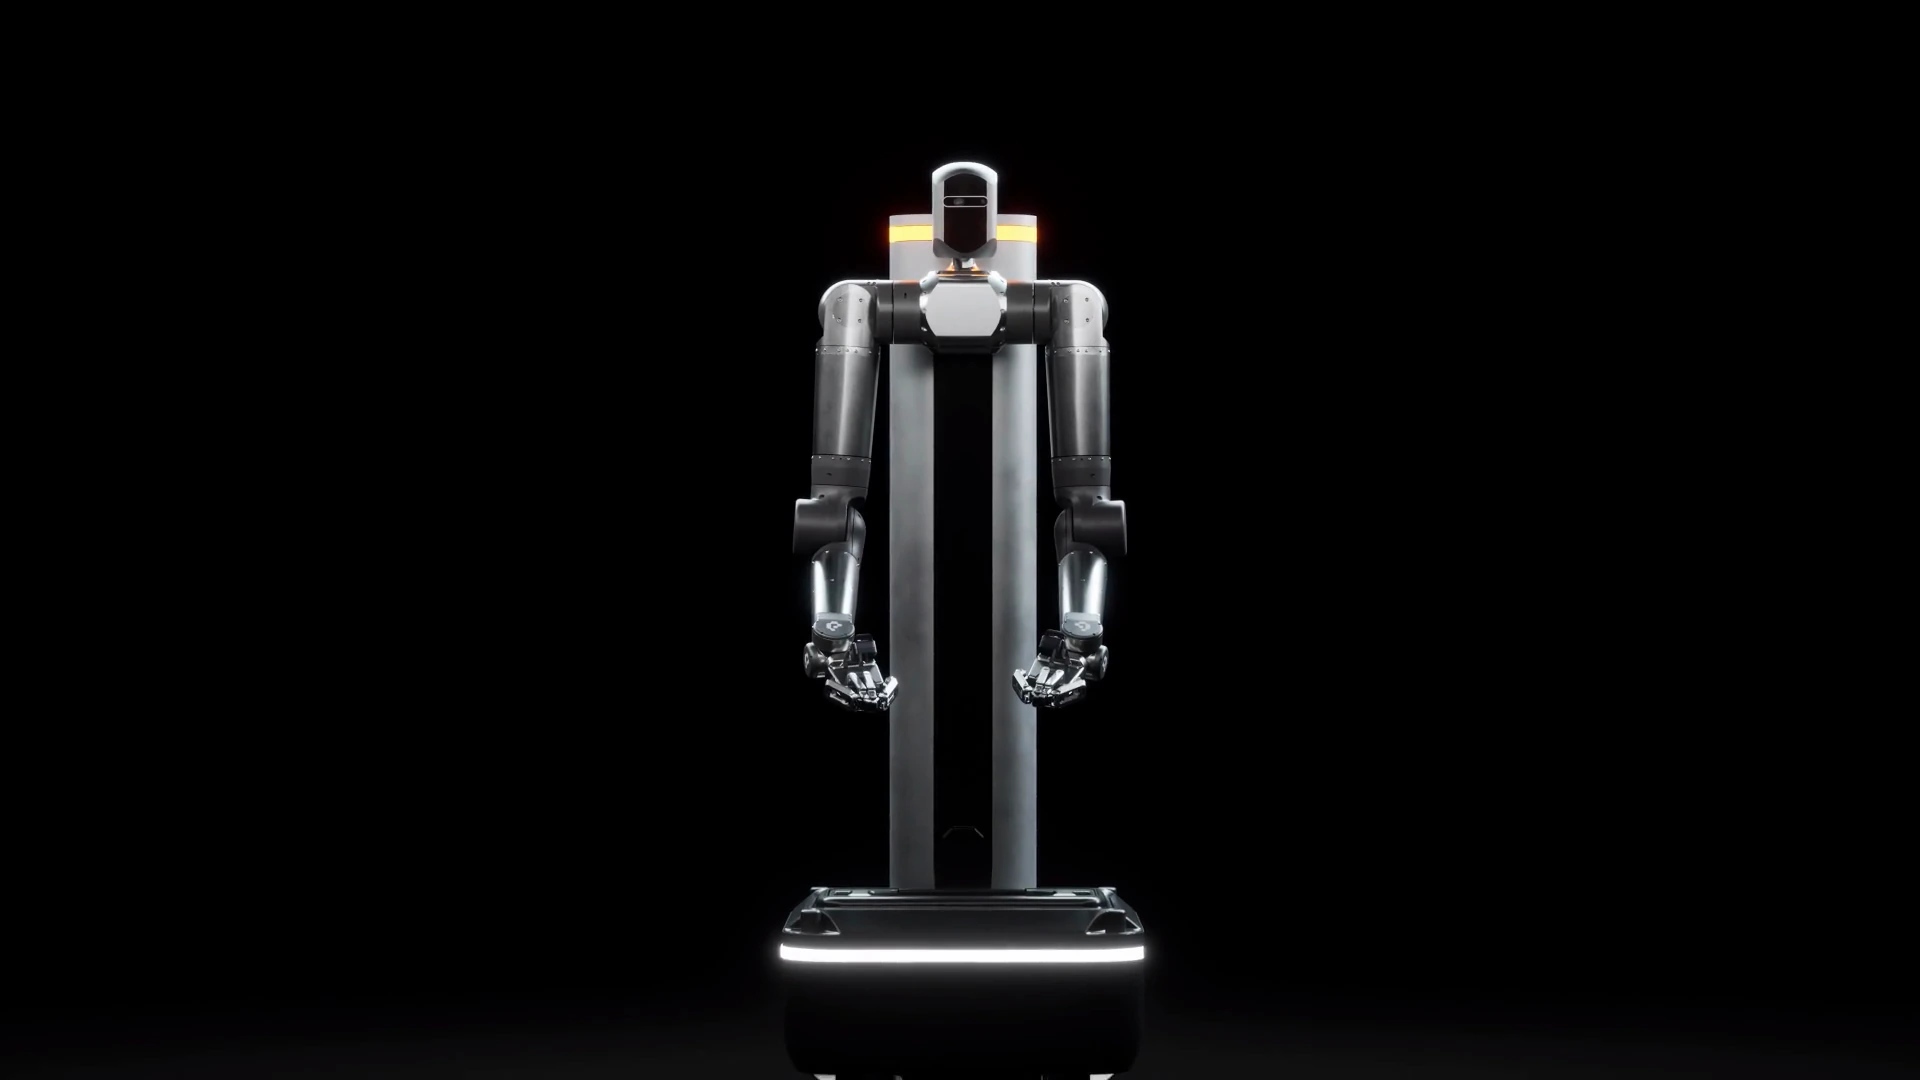
Dual arm · Station
Two coordinated arms on a compact station, for two-handed work in tight spaces.
Explore PR-DUO
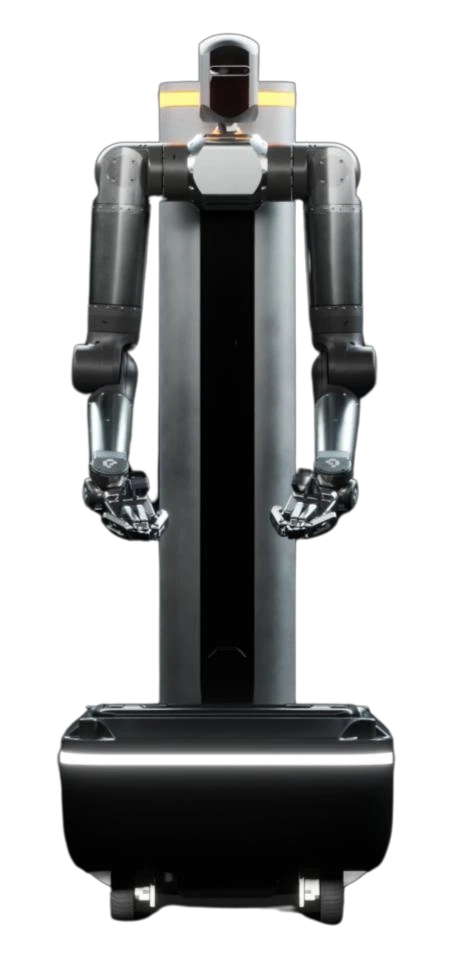
Dual arm · Mobile
A mobile robot that moves between stations and works with both hands.
Explore PR-OMNI
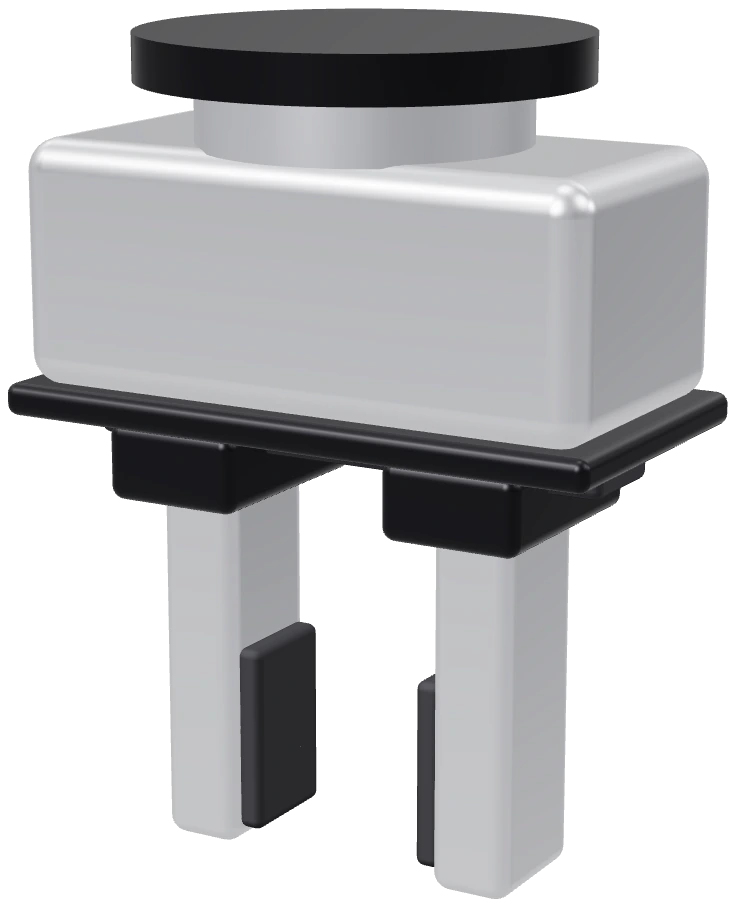
Parallel gripper
Fast, repeatable picks of parts, trays and tools.
Talk to us about the Parallel Jaw Gripper
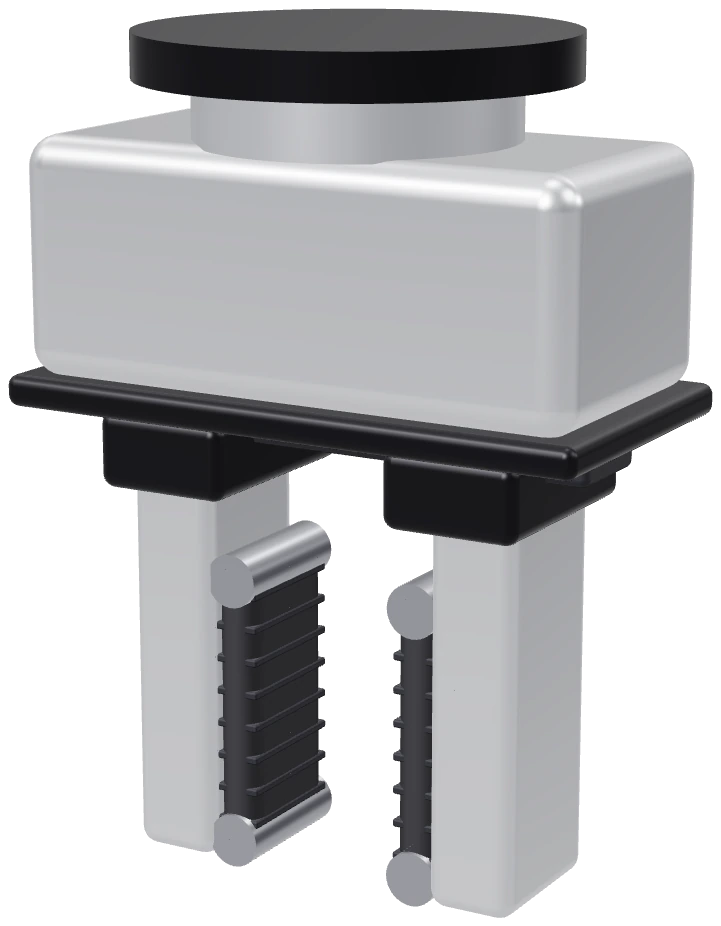
In-hand manipulation
Turns and repositions a part within its grip, so it never has to be set down.
Talk to us about the IHM-A GripperIn-hand manipulation
The next gripper that turns a part within its grip.
TBA

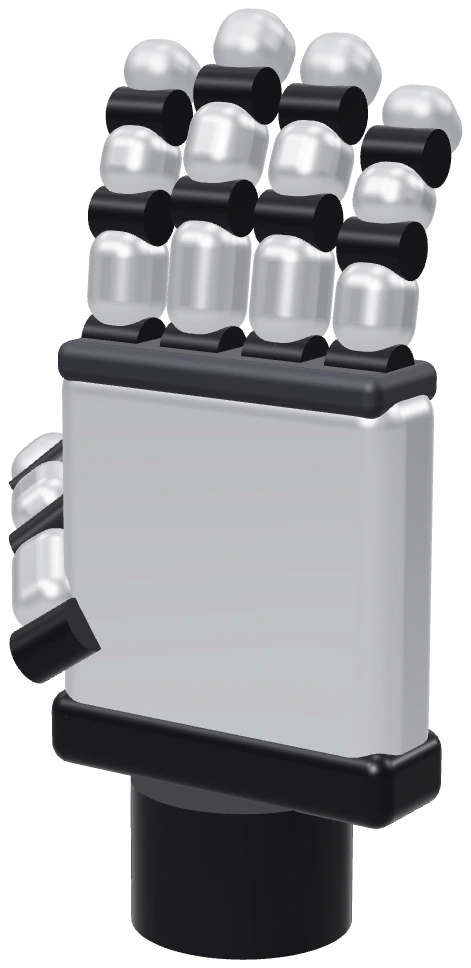
Human-like hand
Fingers that move like ours, for in-hand manipulation and fine assembly, with touch sensing.
TBA

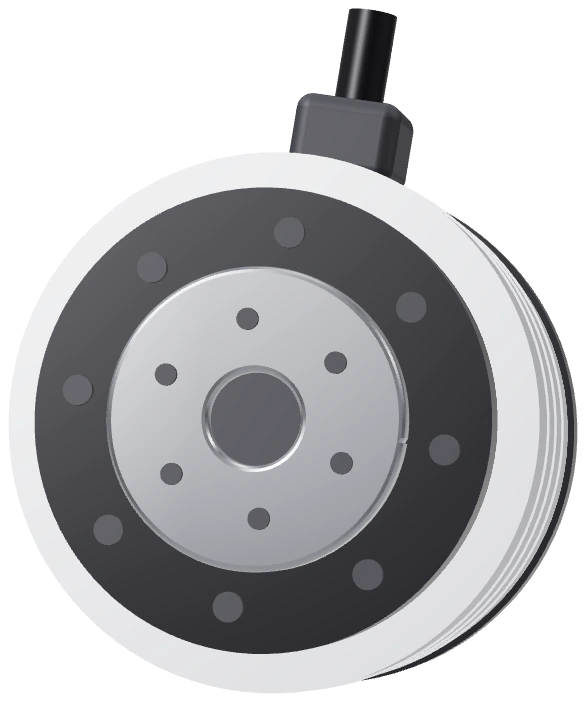
Rotary joints
Compact actuators at the heart of every arm.
Talk to us about joint actuators
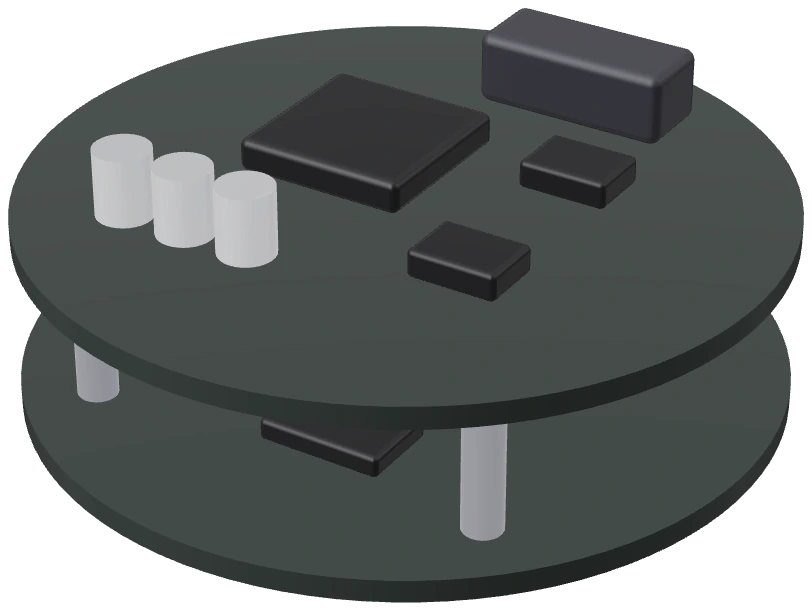
Joint electronics
Drive and sense every joint precisely, in one integrated design.
Talk to us about motor drives and encoders
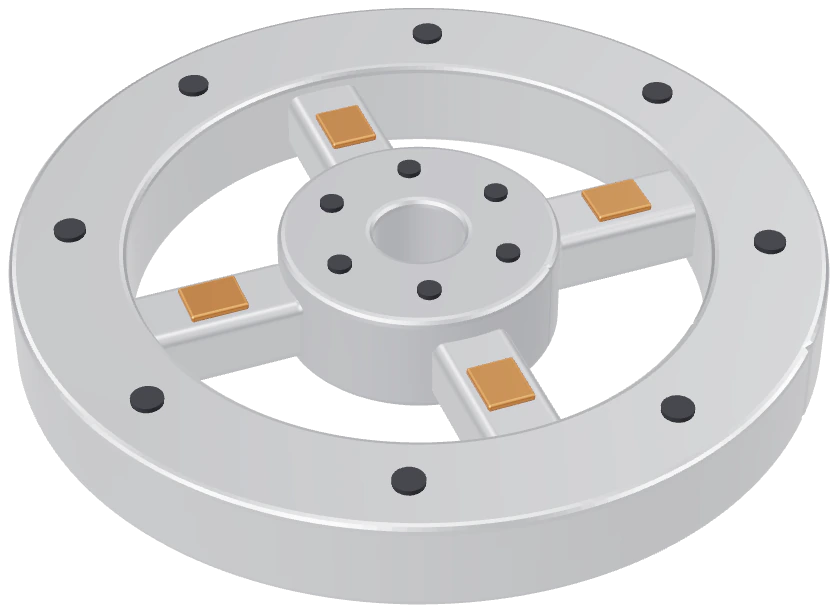
Force at the joint
Measure the force at each joint, for force-aware motion.
Talk to us about torque sensors

